hiding_Easter_eggs 202, search v3c d replay
BEHAVIOR-1K 2026 challenge, issue 74, recov50 scripted recoveries, seed 0, Oct 23 to 29, run v3c_d
Harm gate: accepted. Nothing fell, tipped or moved more than 0.30 m.
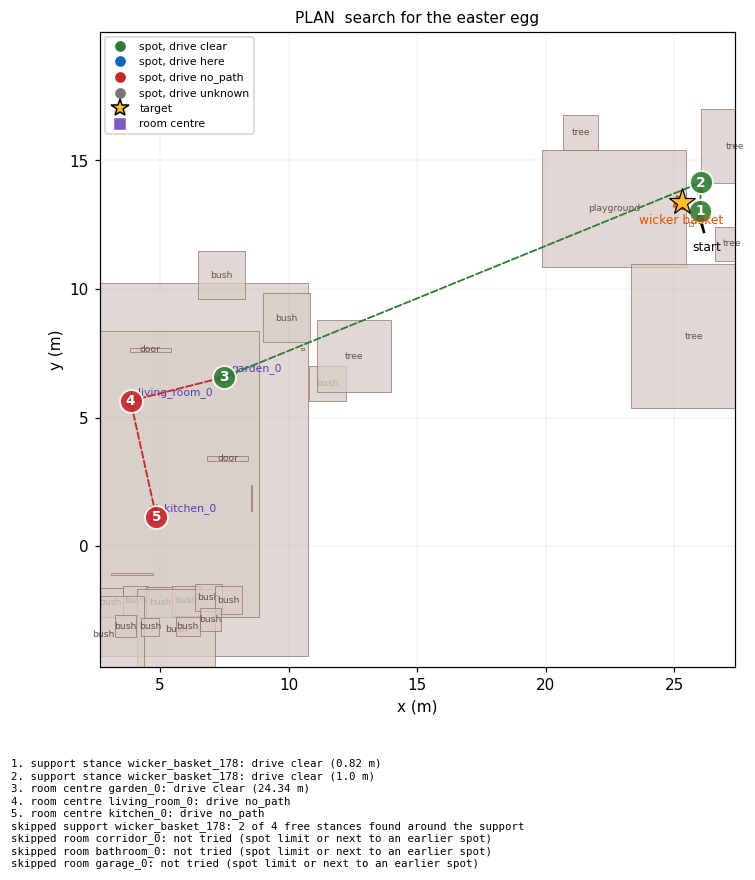
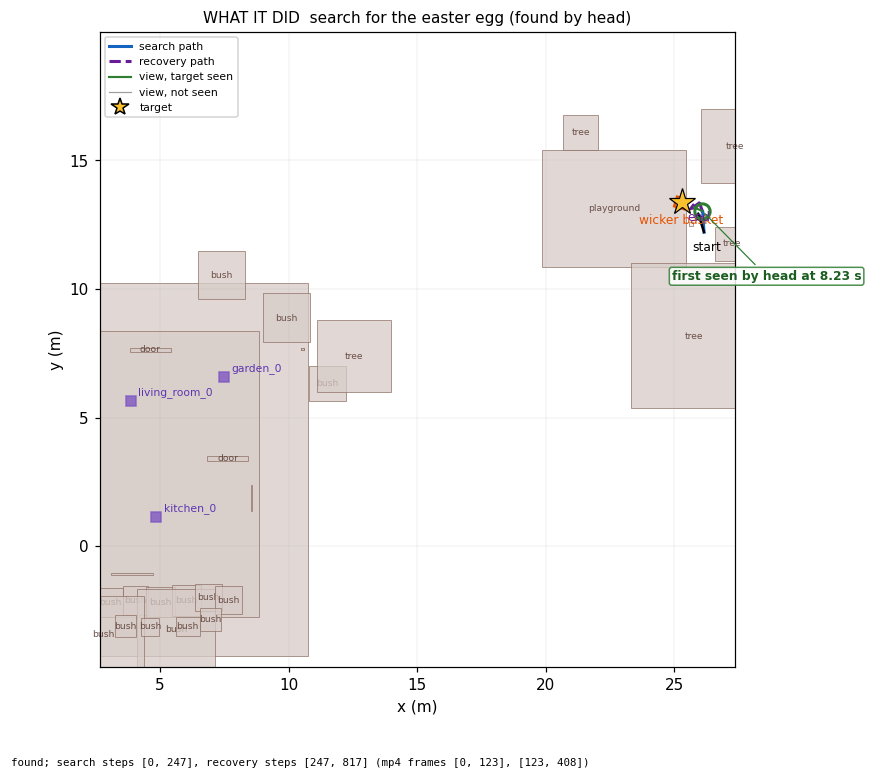
failed The phase is to pick up the easter egg from the wicker basket. The easter egg was out of view at the restore, and the search found it with the head camera after 8 s. The reach plateaued twice and the stall reset fired no times. It ended failed: no grasp fits the gripper (box [0.155, 0.146, 0.131] m, opening 0.11 m).
Other search v2 runs of this case: v3_new_b, failed, v4_d, failed, v5_d, failed, v5b_on_d, failed, v5b_off_d, failed.
The clips play at 2 times sim speed by default, and the speed menu changes that. The timeline shows the recoverer's stage, whether the target is inside the head camera's view while it reaches (from the gaze log), and the labelled events. Click a row to jump there. The robot panel sums up the attempt and the phases list follows the stages.
- Task
- -
- Instruction
- -
- Step
- -
- Sim time
- -
- Q
- -
- Driving
- -
Timeline
Q over time
Robot
- State
- -
Phases
The instruction follows the current phase and moves on when the phase detector confirms it. A typed instruction overrides it until you go back to the task sentence.
Last command
| part | 1 | 2 | 3 | 4 | 5 | 6 | 7 | gripper |
|---|
Look-around
Events
- Nothing yet.
Stage timeline
| stage | from | to | detail |
|---|---|---|---|
| Search | 0:00 | 0:08 | found by the head camera |
| Approach | 0:08 | 0:27 | 3 base moves, 2 reach plateaus, 1 contact |
| Outcome | 0:27 | 0:27 | failed: no grasp fits the gripper (box [0.155, 0.146, 0.131] m, opening 0.11 m) |
Plan and path maps
The plan map is where the search meant to look, from the restore. The path map is where the base went: the search path, then the recovery path.
Earlier attempts
No earlier seed 0 attempt of this case.
All cases. Results come from the attempt's result.json in the recov50 v3c_d run, seed 0.